Why Robot Grippers Shape the Whole Work Cell
Why Robot Grippers Shape the Whole Work Cell
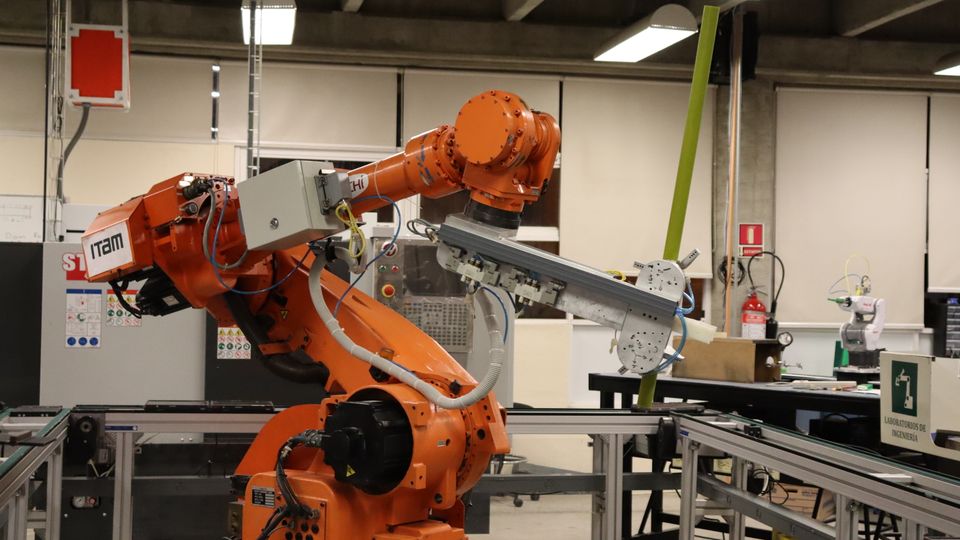
The end tool determines how securely a robot can handle parts across a range of shapes and surfaces.
Vacuum cups can lift smooth panels, while fingers or jaws can engage edges and irregular forms. Tool choice also affects payload, reach and the paths the robot can follow.
Dust, oil or minor changes in surface finish can weaken a grip. Feedback from pressure or force sensors lets the controller recognize a missed pick before it moves farther.
Test the lightest and heaviest parts, worn tooling and poor alignment. A good design leaves time to detect a failed grasp and routes the part back into a known state.